01ORCA hand
ORCA handArticulated reference model
02JY Robot Arm
JY Robot ArmFrom my CAD archive
Robotics / Mechatronics / Making
Kevin Huang.
A little curiosity. A lot of moving parts.
Explore my world01 / THE PERSON BEHIND THE ROBOTS↓
Hi, I’m Kevin Huang
I’m a PhD student at the Mechatronics and Controls Lab at UCLA, advised by Prof. Tsu-Chin Tsao. I work on MR-compatible surgical robotics — hydraulic actuation and hybrid transmissions for robotic manipulation under MRI guidance.
I received my B.S. in Electrical Engineering from NTU (2023) and my M.S. in Mechanical Engineering from UCLA (2026). I like building things across actuators, mechatronics, and control.
Featured Projects
 hybrid
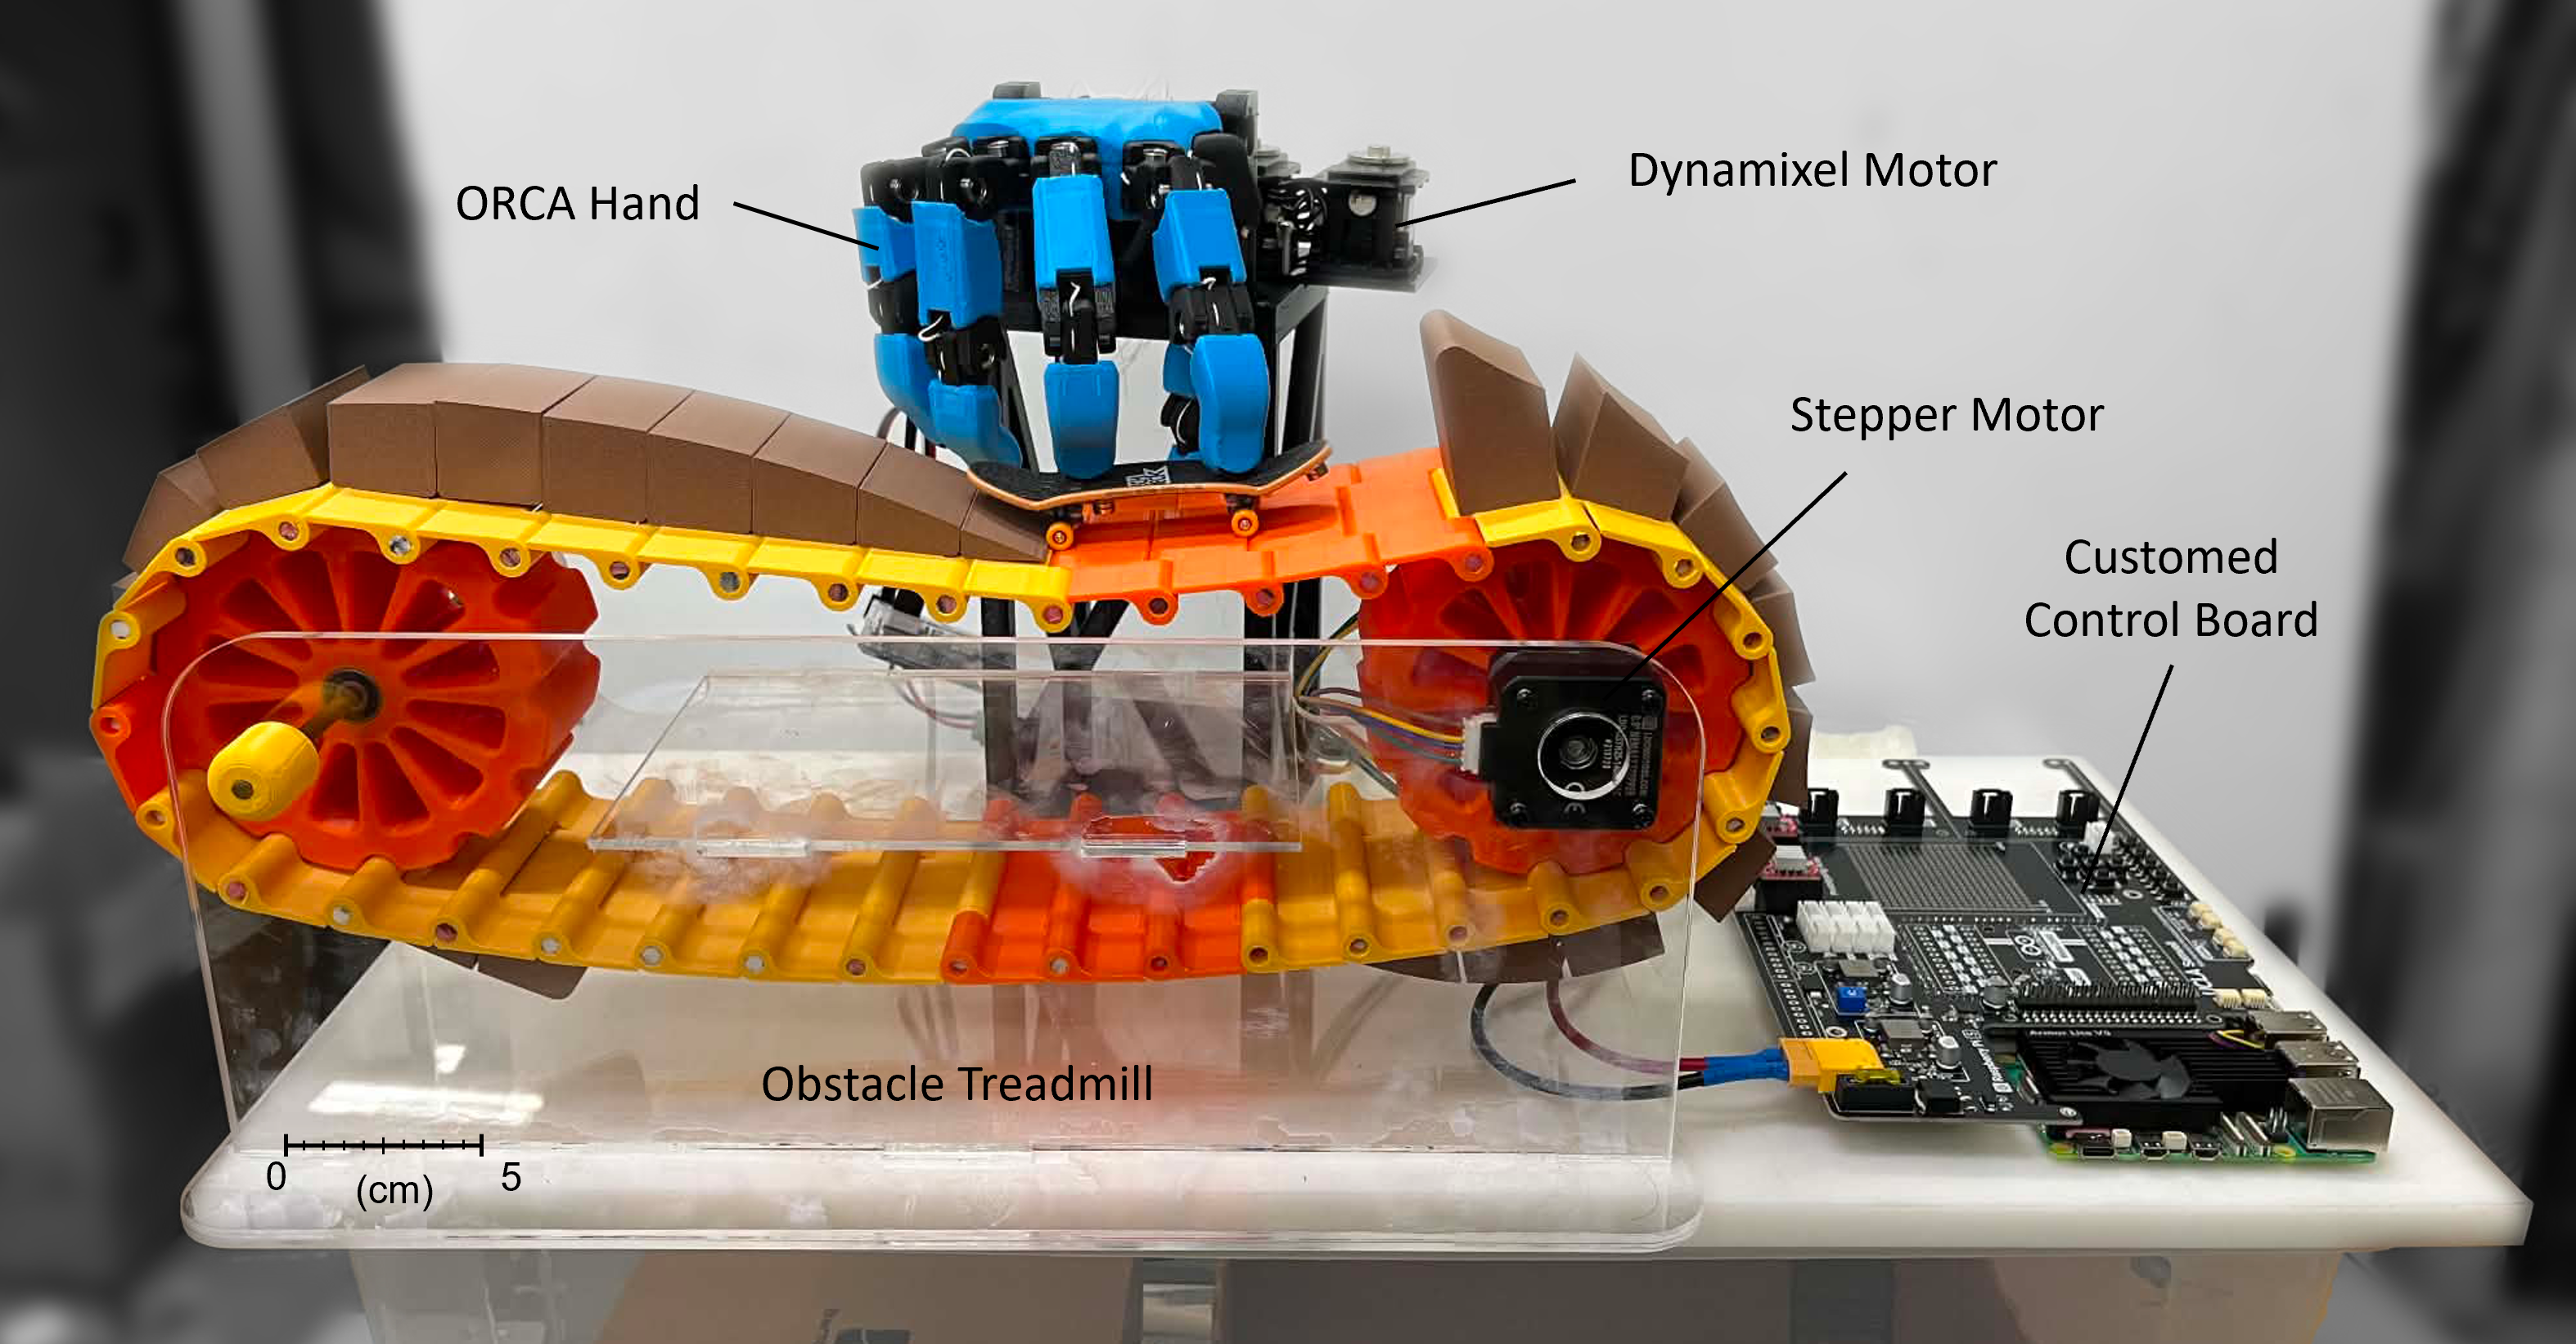
FingerSurfer
A tendon-driven robotic hand that finger-skateboards over an obstacle treadmill — exploring dexterous manipulation and sensorless force estimation for UCLA MECH&AE C263C.
View project
 hybrid
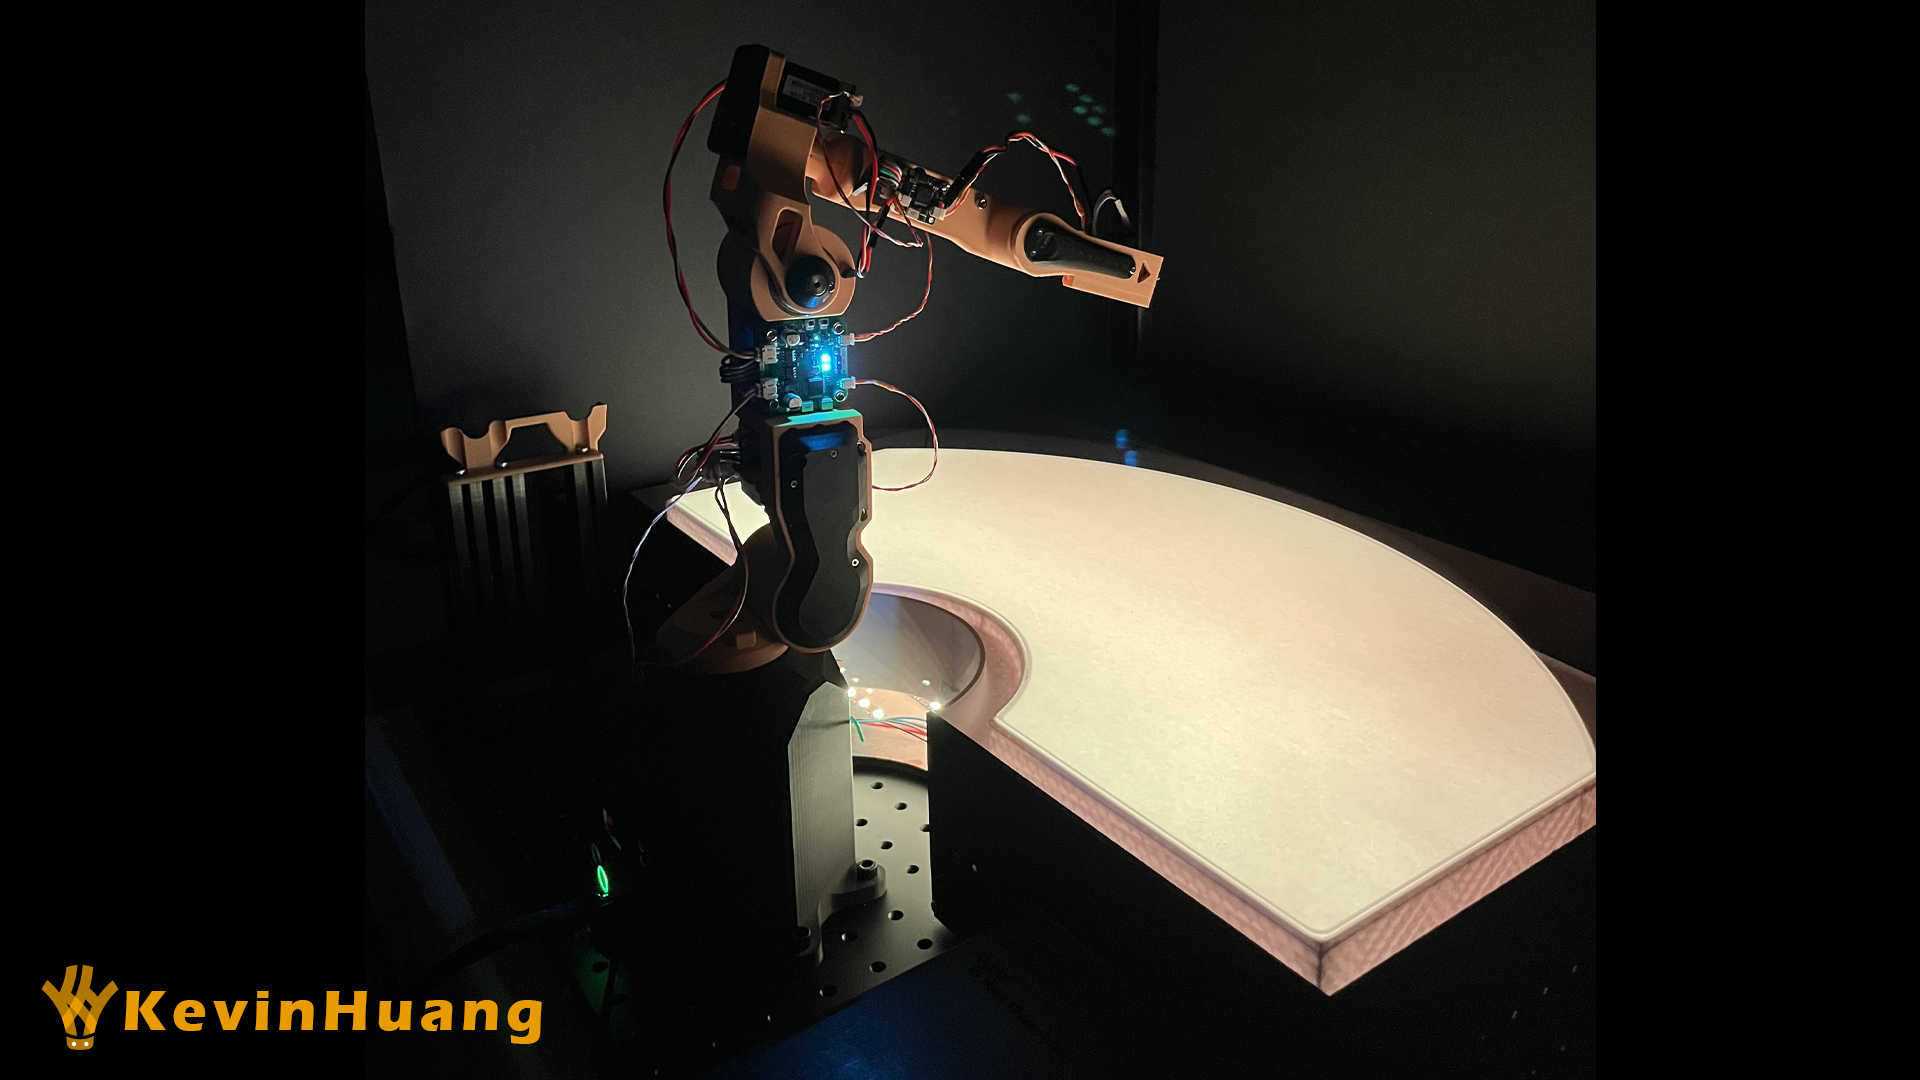
SandArt Robot
A 3D-printable sand-painting robot arm derived from Dummy-Robot, with redesigned mechanics, custom STM32 motor-control PCBs, and biomimetic sprinkler and scraper end-effectors.
View project
 hardware
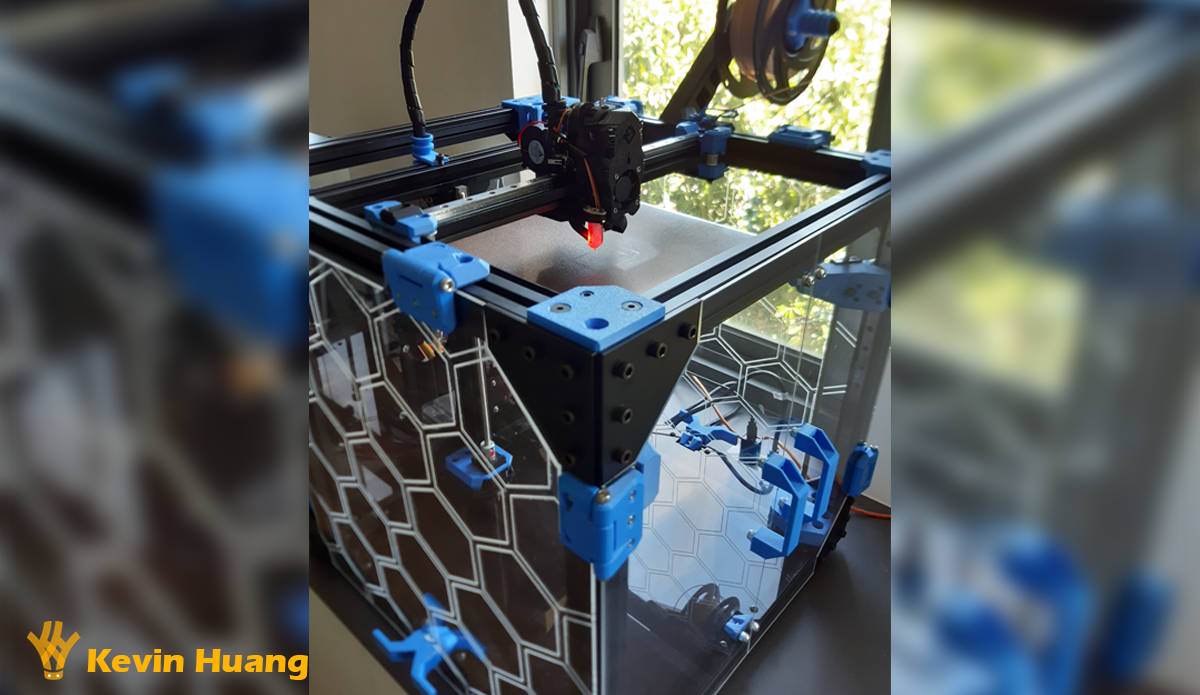
3D Printer V-CORE 3
A from-scratch build of the open-source RatRig V-CORE 3 — CoreXY motion, custom wiring, and tuning for fast, high-quality prints.
View project